Small robot propulsion: low-power twisting enables hopping, swimming
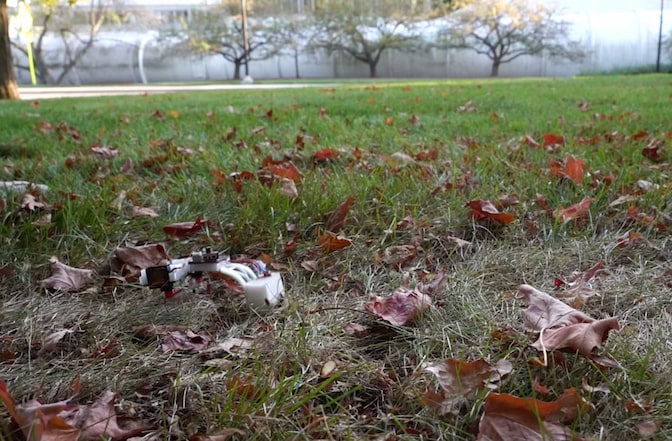
The mechanism works on challenging surfaces such as slippery cloth and grass-covered ground, producing frog-like motion.

The mechanism works on challenging surfaces such as slippery cloth and grass-covered ground, producing frog-like motion.
Watch the extended audio-described version of this video on MiVideo . Once the MiVideo player loads, select the AD button in the lower right controls to activate the extended audio description.
On-screen text:
Achieving powerful motion with low-power motors is a challenge in robotics. Now, researchers at U-M and UCLA have revealed a new mechanism. Their demonstration robot hops like a frog.
And with paddle attachments, it can even swim. They achieved this by twisting the ends of bent, flexible rods.Once the rods hit a maximum contortion, they can snap back to a more relaxed position.
The team used computer simulations to discover how to make the rods reliably snap, rather than slowly twist into the more relaxed position. The new mechanism could enable tiny robots to maneuver over slippery or uneven terrain.
The test devices could even climb stairs, and achieve speeds of about three body lengths per second, similar to loggerhead turtle hatchlings as possible, as soon as possible.
The twisting of bent elastic rods can produce a snapping motion that enables small robots to hop or swim, roboticists at the UCLA Samueli School of Engineering and the University of Michigan Engineering have demonstrated.
The advance offers a promising mechanism for robots with limited power, particularly miniature robots, according to the research team. The study was funded by the National Science Foundation.
Published in Science Advances, the research was co-led by Khalid Jawed, an associate professor of mechanical and aerospace engineering at UCLA, and Xiaonan (Sean) Huang, an assistant professor of robotics at U-M.
“The broader opportunity is to let the mechanics of the robot do some of the work that would otherwise require larger motors or more complicated control,” said Huang. “By programming when an elastic structure stores and rapidly releases energy, we can give small robots access to powerful, repeatable motions without continuously demanding high output from the motor. In the future, this principle could be useful for robots that must navigate cluttered terrain, overcome obstacles, reorient quickly or operate across both land and water.”
When a flexible rod is bent, and its ends are rotated, it eventually reaches a point where it changes shape to release built-up tension—but this change does not always happen in the same way. Under some combinations of bending and twisting, the rod changes shape gradually. Under others, it snaps rapidly from one shape to another, with the potential to provide a strong push.
Through computer modeling and experiments, the team optimized a helical shape, like a segment of a coiled spring, that maximized the burst of energy while resetting quickly for the next snap.
“Because it’s the rod’s shape — not its size — that determines whether it snaps sharply or deforms gradually, the same design rules apply across a wide range of scales,” said Jawed, whose lab worked on the simulation and robot arm experiments. “This opens a promising path toward robots just a few millimeters wide, turning small motor movements into powerful bursts of motion.”
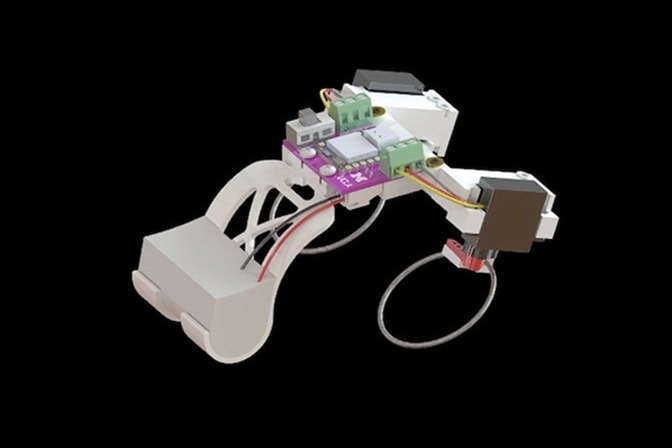
After optimizing the propulsion mechanism, the team designed and built real robots that use the snapping rods to hop. Connected to a rotating motor, the bent rods twist until they produce the snapping motion. Then the motor unwinds the twist and proceeds to contort the rod again.
“Once we could predict when a rod would snap, we could use that sudden release of energy to turn a simple motor movement into a powerful push that sends the robot hopping forward,” said U-M postdoctoral scholar Dezhong Tong, the study’s co-lead author with Jiaqi Wang, a PhD student in robotics at U-M. Tong started working on the project while a graduate student in Jawed’s group at UCLA.

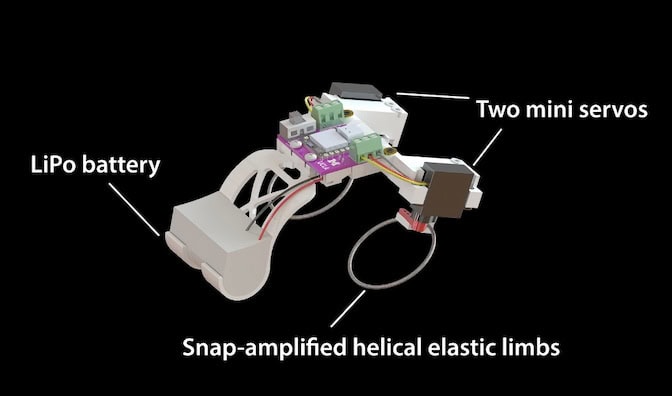
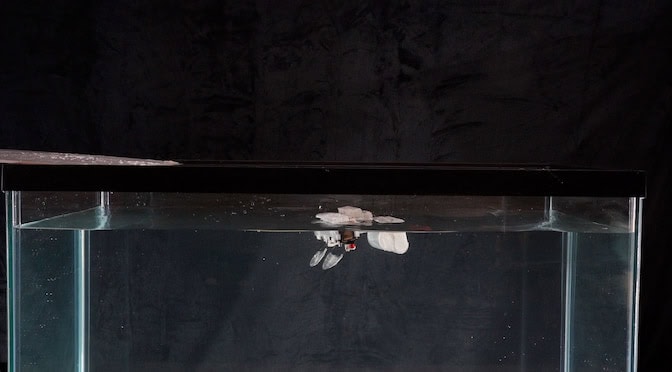
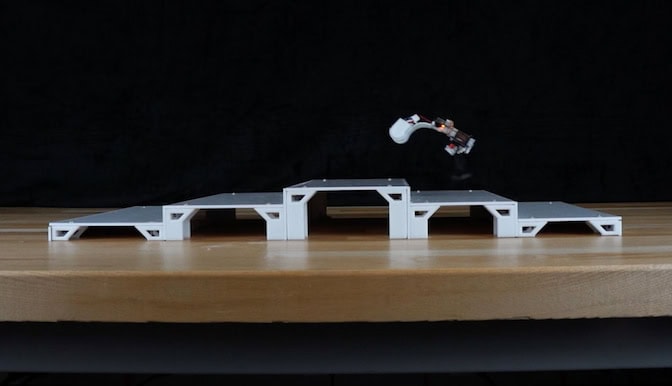
The frog-like prototype, with a pair of snapping rods at the rear of the device, hopped over a broad range of test surfaces—from solid materials like wood and glass to soft and slippery materials like leather. Outside, the palm-sized robot tackled sand and grass. It could climb and descend steps and, with paddle attachments, could even swim.
Moving the two snapping rods at different rates enabled the robot to turn, and the team used a remote control to maneuver the robot around a small sandbox with rock obstacles. They also automated a simple navigation method, using light sensors so that the robot would approach a light source.
The small prototype, weighing about 0.25 lbs, could move about three body lengths per second—similar to a baby loggerhead turtle making its way to the sea.
Other study authors include Zexiong Chen, a former graduate student at the University of Michigan; Andy Borum, an assistant professor of mathematics and statistics at Vassar College in New York; and Weicheng Huang, a lecturer/assistant professor of mechanics and robotics at Newcastle University, U.K.
Story by Matthew Chin, UCLA Samueli.